Collaborative applications and shared zones
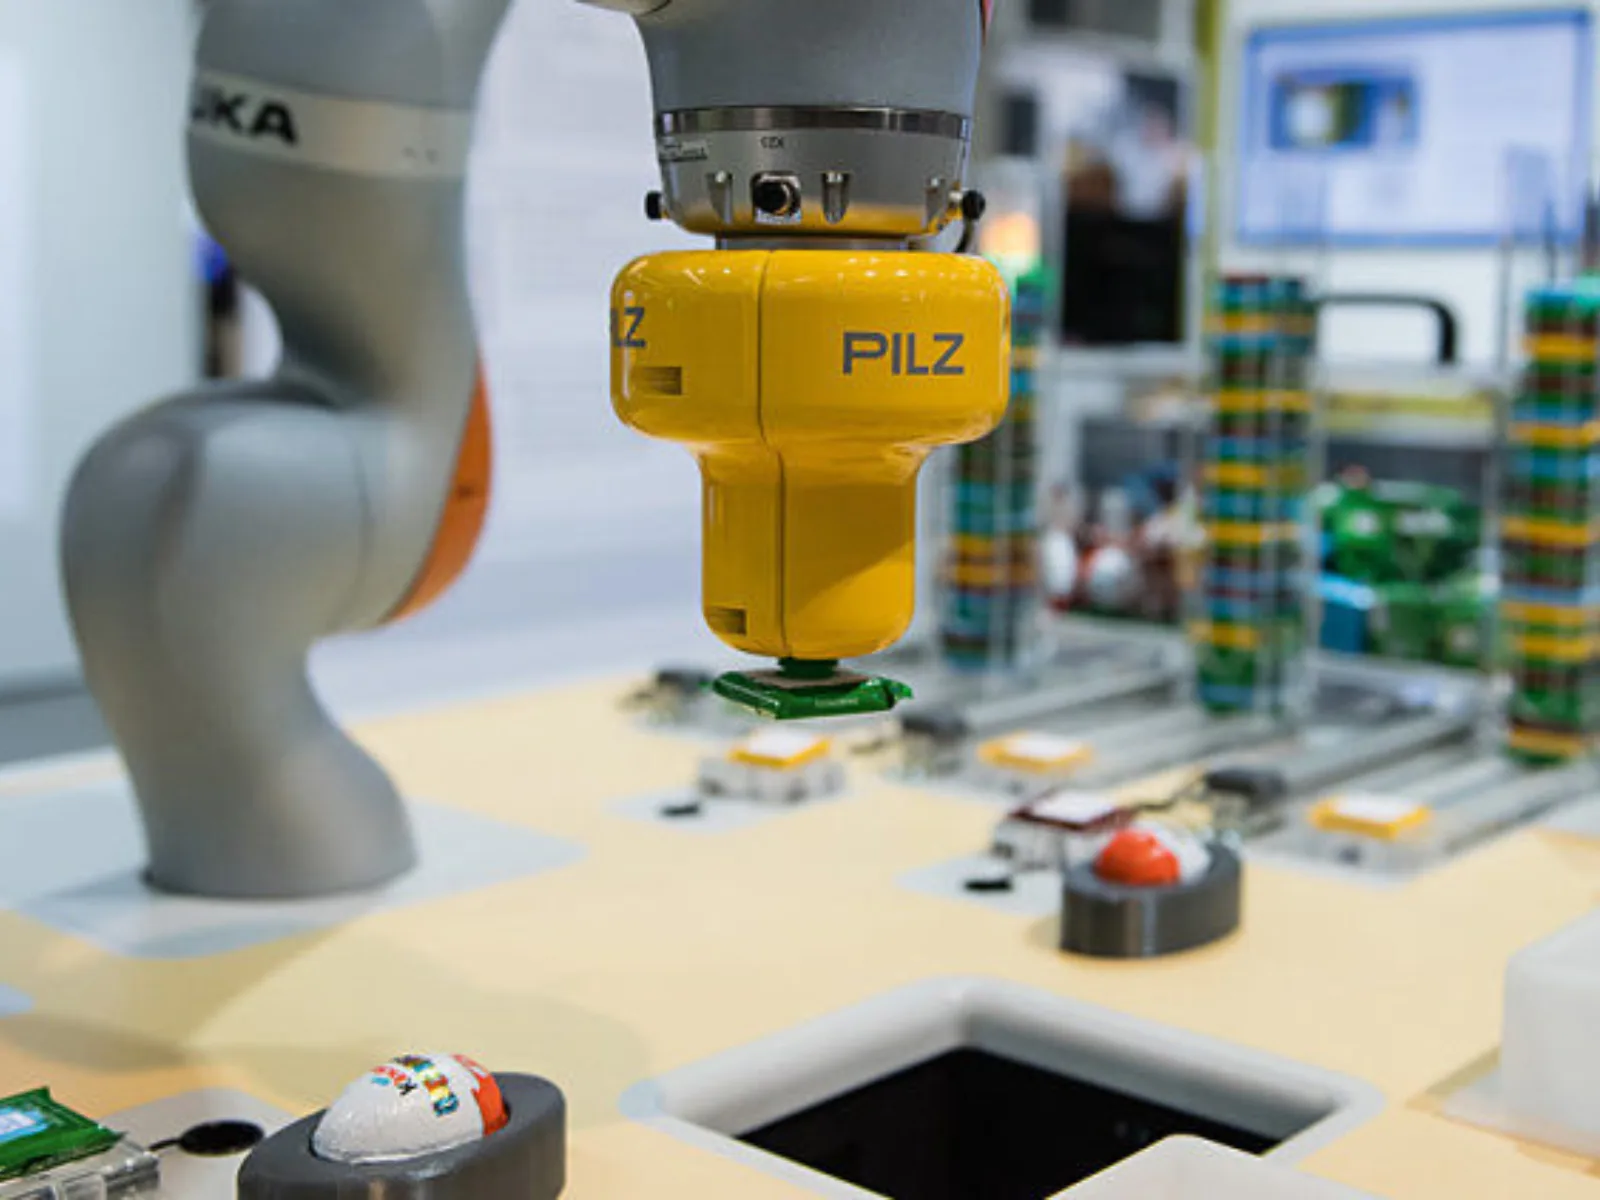
An unguarded robot working next to a person depends on the whole application being safe, not just the arm. With a gripper, a cutting tool or a heavy load, the robot's force limitation is no longer enough. If the robot always runs at reduced speed to cover that risk, the cycle becomes slow and the application no longer pays off.
PSENscan laser scanner (3 or 5.5 m range): defines 2 warning zones and 2 protective zones around the robot, with up to 10 switchable configurations. When a person enters the warning zone, the robot slows down; when they enter the protective zone, it stops. When the person moves away, the robot returns to normal speed without intervention. PNOZmulti 2 evaluates the zones and commands the robot controller, with 20 inputs and 4 safe outputs, SIL 3, PLe, and Profinet, EtherNet/IP or Profibus modules.
PSENradar safety radar: volumetric presence detection up to 4, 5 or 9 m depending on sensor, PLd, Cat. 3, unaffected by dust, steam or lighting conditions. It detects the person in the working volume, not only on the floor plane, and prevents restart while they remain there.
- PILZ PSENscan laser scanners
- PILZ PSENradar radar systems
- PILZ PNOZmulti 2 configurable relays